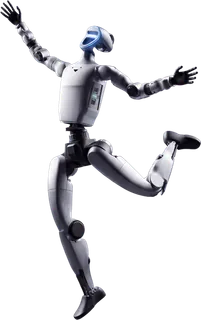
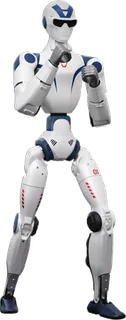
Unitree G1 vs Unitree R1
Better figure, where one is clearly better
| UnitreeG1 | UnitreeR1 | |
|---|---|---|
| Overview | ||
| Released | – | – |
| Task and control | ||
| Form | Humanoid | Humanoid |
| Use | Education, Research | Education, Research |
| User programming | No / Yes | No / Yes |
| Phone app | Yes | Yes |
| Intended use | Humanoid movement demonstrations and robotics research; the EDU configuration supports secondary development. Demonstrated dexterous manipulation does not establish standard out-of-box household work. | Motion demonstrations and education/research; EDU is the version for supported secondary development. A humanoid shape does not establish useful autonomous household labour. |
| Movement | Standard G1 has 23 joint degrees of freedom, including six per leg, five per arm and one waist joint. EDU has 23–43 depending on optional waist, wrist and dexterous-hand joints. Standard joint movement ranges include knee 0–165° and waist rotation ±155°. | Six degrees of freedom per leg. Air has four per arm; standard and EDU have five per arm plus two waist and two head degrees of freedom. EDU can be configured with additional hand joints, taking its total from 26 to as many as 40. |
| Autonomy | The maker describes imitation and reinforcement learning and its UnifoLM model. It explicitly warns that some example functions remain in development/testing; those demonstrations do not prove autonomous general-purpose work in the purchased base configuration. | The maker describes multimodal voice and image interaction, but warns that some example functions shown are still being developed and tested. Standard motion routines are distinct from general autonomous manipulation. |
| User programming | Standard G1 does not support secondary development; EDU supports it. EDU can add optional compute modules such as Orin. The store also offers a G1 Pro variant, but its exact distinct specification is not published in the G1/EDU table used here; do not assume that Pro is EDU. | The exact current comparison marks secondary development absent on Air and standard R1, supported on EDU. EDU offers optional computing and dexterous hands; these are not standard features of the entry models. |
| Remote control | Handheld controller included; maker G1 app available. | Handheld controller included in the maker's comparison; the maker also provides its R1 app. |
| Regional availability | The official global store accepts orders for G1 and G1 Pro; it gives delivery details upon request rather than a guaranteed immediate delivery date. EDU requires contact with sales. Freight and local customs/import clearance apply. Checked October 2026. | The official global store lists Air, standard and EDU variants as available for ordering, with an In Stock heading. Additional EDU accessories require contact with sales. Shipping/import clearance conditions apply; individual destination delivery is not established by the headline. Checked October 2026. |
| Release details | Unitree confirms the initial announcement on 13 May 2024 and a mass-production version on 19 August 2024. Neither announcement establishes the first retail delivery date, so that date is left unpublished. Current specifications use the maker's 1,320 mm height rather than its earlier 1,270 mm event wording. | Contemporary launch coverage dates the announcement to 25 July 2025. The first retail delivery date is not established; the December 2025 store publication timestamp is not treated as first sale. |
| Hardware | ||
| Degrees of freedom | 23 | 20–26 |
| Height | 1,320 mm | 1,230 mm |
| Width | 450 mm | 357 mm |
| Depth | 200 mm | 190 mm |
| Robot weight | 35 kg | 27–29 kg |
| Camera | Yes | Yes |
| Microphone | Yes | Yes |
| Wi-Fi | Yes | Yes |
| Bluetooth | Yes | Yes |
| Processing | Eight-core high-performance CPU. EDU optionally accepts additional computing modules including Orin; no exact standard CPU model is specified. | Eight-core high-performance processor across the range. EDU optionally supports additional high-power computing modules, including Orin configurations; no exact standard processor model is published. |
| Sensors | Depth camera and 3D LiDAR; dual joint encoders. | Air monocular camera; standard R1 and EDU binocular camera. Joint encoders are described as dual plus single encoders. |
| Camera | Depth camera is listed across G1 and G1 EDU. No camera image-resolution figure is published in the exact table used. | Monocular on Air; binocular on standard and EDU. Camera presence is not proof of depth-map accuracy or independent navigation performance. |
| Audio | Four-microphone array and 5 W speaker. | Four-microphone array and speaker across the range. |
| Actuators | Permanent-magnet synchronous motors, industrial crossed-roller bearings and local air cooling. Maximum largest-joint knee torque 90 N·m for G1 or 120 N·m for EDU; not every motor has that torque. | Low-inertia high-speed inner-rotor permanent-magnet synchronous motors with local air cooling. Knee movement −10° to +139°; the maker's numerical joint limits are not an agility score. |
| Payload | Arm maximum load approximately 2 kg for G1 or 3 kg for EDU, depending strongly on arm-extension posture. This is not a whole-body carrying payload. | Maker arm-load claim about 2 kg, varying greatly with arm extension. Its table labels this row Maximum Torque of Arm Joint but gives kilograms and a load footnote; it is not a published N·m torque figure. |
| Connections | Wi-Fi 6 and Bluetooth 5.2. | Wi-Fi 6 and Bluetooth 5.2. |
| Size and weight | Standing height × width × thickness 1,320 × 450 × 200 mm; folded 690 × 450 × 300 mm. Standard weight about 35 kg with battery; EDU is about 35 kg or more depending on equipment. Current maker photographs can show optional dexterous hands, which are not supplied with the standard G1. | Standing height × width × thickness 1,230 × 357 × 190 mm. Weight with battery approximately 27 kg for Air and 29 kg for standard/EDU. The current specification supersedes the approximately 25 kg wording in initial launch coverage; optional EDU attachments may alter the supplied configuration. |
| Accessories | EDU optionally adds two waist joints, two wrist joints per hand and force-controlled three-finger Dex3-1 hands; each hand has seven active finger degrees of freedom. Tactile arrays are optional. Photo captions identify shown optional equipment. | Optional dexterous hands and additional computing modules are EDU-specific. Maker store renders are explicitly labelled prototype images; their exact appearance can differ from supplied hardware. |
| Battery | ||
| Battery life (maker's claim) | About 2 hours | About 1 hour |
| Battery capacity | 9,000 mAh | – |
| Battery | Quick-release 9,000 mAh lithium battery, described as a 13-series pack. | Quick-release lithium battery; capacity is not published in the exact current R1 table used. |
| Charging | Supplied charger 54 V 5 A; no exact charging duration is published in the table used. | Charger supplied; the current comparison does not publish a charge-time claim. |
| Runtime conditions | About two hours is the maker's battery-life claim for G1 and EDU, without a detailed published workload test; conditions and configurations can alter actual runtime. | About one hour is the maker's claim across configurations, without a detailed workload test. Actual performance varies with scenarios and configurations. |